Compare
NEO Gamma vs PM01
Quick verdict
NEO Gamma leads on 7 of 11 comparable rows
NEO Gamma leads on Readiness Score, Speed, Battery, and Price (+3 more). PM01 leads on Data Freshness, Mobility, Perception, and Autonomy.
The lead is a count of published spec rows, not an in-home test.
Who should choose which?
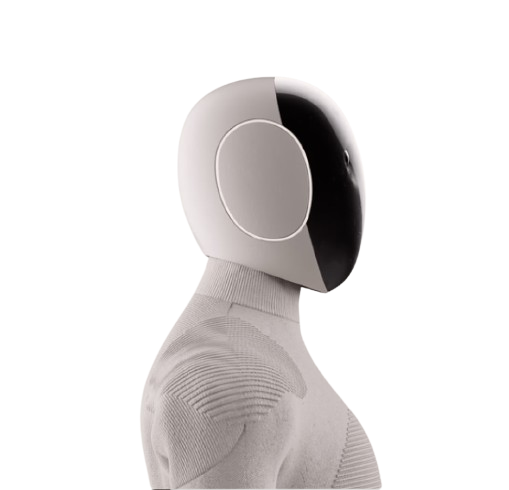
Choose NEO Gamma if…
- Budget is a priority and NEO Gamma lists lower ($20,000).
- Strengths like social interaction and manipulation match how you plan to use it at home.
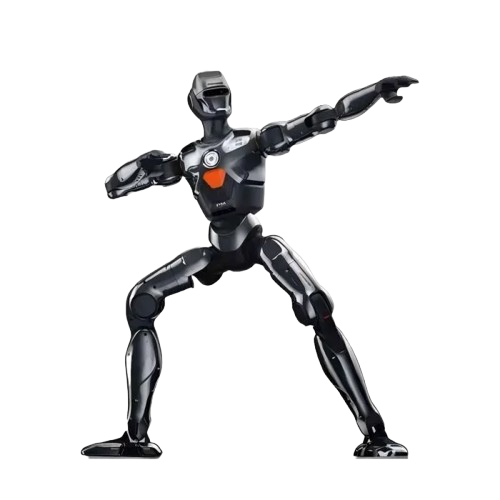
Choose PM01 if…
- Strengths like mobility and perception match how you plan to use it at home.
Scoreboard
- NEO Gamma★wins 7
- PM01wins 4
Choose NEO Gamma if…
- Budget is a priority and NEO Gamma lists lower ($20,000).
- Strengths like social interaction and manipulation match how you plan to use it at home.
Choose PM01 if…
- Strengths like mobility and perception match how you plan to use it at home.
| Performance | ||
|---|---|---|
| Readiness Score | 88 | 87 |
| Reality Score | 78 | 78 |
| Data Freshness | 85% | 100% |
| Speed | 5 km/h walk (1.4 m/s) | >2 m/s |
| Payload | 8 kg arm / 25 kg carry | Unknown |
| Specs | ||
| Height | 168 cm | 140 cm |
| Weight | 30 kg | 44.5 kg |
| Battery | 4 h | 2 h |
| Form | Humanoid | Humanoid |
| Availability | ||
| Price | $20,000 | $26,000 |
| Market Status | Pre-order | Buy Now |
| Availability | Limited | Limited |
| Countries | United States | China |
| Intelligence | ||
| Mobility | 82 | 90 |
| Manipulation | 86 | 76 |
| Perception | 80 | 82 |
| Autonomy | 58 | 68 |
| Social Interaction | 88 | 52 |
| Home Navigation | 84 | 68 |
| Sensors | Dual 8.85MP stereo fisheye cameras, 4 beamforming mics, IMU | Dual wide-angle binocular cameras (head and waist); 3D LiDAR on 2026 navigation trim; voice I/O |
| Connectivity | Wi-Fi, Bluetooth, 5G | Wi-Fi, Ethernet |
| Ecosystem | Redwood AI; 1X Expert remote guidance; Chores scheduling app | ROS / ONNX deployment; MuJoCo sim2sim; Isaac-based training code; Jetson Orin NX dev stack (education); Quick-swap battery pack |
Green cells mark the stronger value in each row across 2 robots.